
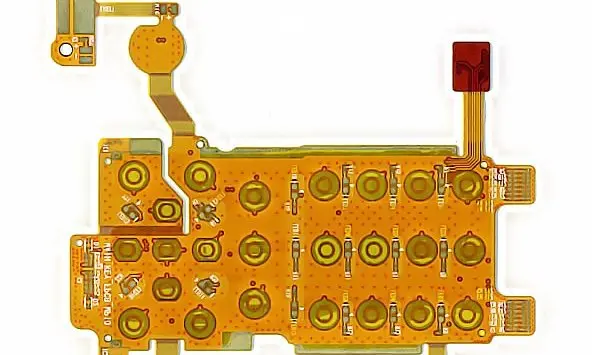
Describe the joint’s local operating duty
Record the movement of the flex mounts through normal trajectories, teaching, parking and servicing. Include reversals and any pauses that hold the circuit in a constrained shape. The bend-planning guide helps define the actual geometry and its radius convention without predicting service life.
Collaborative-robot joint review
| Concern | Input | Verification focus |
|---|---|---|
| Repeated trajectories | Mount movement and reversals | Representative routing duty |
| Compact joint | Covers, fasteners and components | Clearance in every pose |
| Service replacement | Access and connection sequence | Repeatable installation |
Keep joint loads out of electrical interfaces
Show the relationship between the flex, actuator, encoder and housing covers. Identify restraint points and protection from fasteners or moving hardware. Review stiffener placement so connector support ends and flexible spans have an intentional transition.
Separate power and feedback requirements in the electrical brief. Document the complete feedback interface and its acceptance criteria with the controls team. The interconnect design must be evaluated within the robot system; a bare circuit test cannot establish the machine’s safety functions.
Plan measurable maintenance and endurance evidence
Define inspection access, replacement instructions and any product-level service interval through the responsible engineering team. Prototype tests should reproduce the route and mounts with agreed motion and environmental conditions. Record how electrical interruptions and visible damage are detected. Where a route change is proposed for easier assembly, assess whether the existing endurance evidence still applies.
Before you release the design
- Include teaching and servicing poses in the envelope.
- Define feedback and actuator interconnect requirements separately.
- Protect connectors from joint and maintenance loads.
- Agree motion-test detection methods and failure criteria.
Watch points
- A route qualified in one joint cannot be assumed equivalent after mounts, covers or trajectory limits change.
Practical questions
Does collaboration with people change the flex specification?
The system owner must determine applicable requirements. Translate relevant product risks into concrete electrical, mechanical, documentation and verification inputs for the interconnect.
Can joint angle be used as the only test input?
No. Include attachment geometry, local route, speed, reversals, environment and detection criteria so the circuit experiences representative conditions.
Technical references
References support the material or design context. Check the exact grade, part number, document revision and project conditions before release.Updated 27 September 2026 · Technical content policy · Engineering guidance supports project review; the agreed drawing defines the build.